Robotics Knowledge Hub
The definitive engineering guides covering the indispensable physical and algorithmic pillars of modern robotics: Embedded Compute & Protocols, Control Systems & Kinematics, ROS 2 & SLAM, and Computer Vision & Edge AI.
Featured Knowledge Topics
Click on any topic tile to read the complete technical guide with comparison tables, formulas, and code.
Microcontrollers in Robotics
Master modern robot compute: MCU architecture, GPIO current limits, ADC sampling, hardware timer PWM, ISR latency, and choosing between Arduino, ESP32, Pico, and STM32.
- MCU vs SBC: Real-Time Determinism vs High-Level Compute
- Core Architecture: Clock, Flash, SRAM, and Bus Matrices
- Peripherals: GPIO, ADC Resolution, and Hardware PWM Timers
- Hardware Interrupts (ISRs) for Encoders and Safety Limits
- Platform Face-Off: ATmega328P vs ESP32 vs RP2040 vs STM32
- Robotics Selection Matrix: Which Controller for Which Robot
Communication Protocols in Robotics
Master how robot components exchange data: UART, I2C, SPI, CAN bus, and Ethernet compared for throughput, wiring distance, noise immunity, and real-time reliability.
- UART: Asynchronous Serial, Baud Rates, and RS-485 Differential Upgrades
- I2C: Two-Wire Bus, Addressing, Pull-Up Resistor Sizing, and Bus Capacitance
- SPI: High-Speed 4-Wire Synchronous Bus, Master-Slave, and Chip Selects
- CAN Bus: Differential Signaling, ISO 11898, 120Ω Termination, and Arbitration
- Industrial Ethernet & ROS 2: High-Bandwidth LiDAR, Vision, and DDS Transport
- Protocol Selection Matrix: Matching Physical Layer to Robot Subsystems
Robot Control Systems
Master modern robot feedback control: Open-loop vs closed-loop, error dynamics, quadrature encoder decoding, PID mathematical formulation, anti-windup clamping, and tuning methods.
- Open-Loop vs Closed-Loop: Why Disturbances Break Open Systems
- Feedback Architecture: Setpoint, Error Dynamics, and Plant Output
- Sensors as Truth: Quadrature Optical and Magnetic Encoder Decoding
- The PID Algorithm: Proportional, Integral Anti-Windup, and Damping Derivative
- Tuning in Practice: Ziegler-Nichols, Step Response, and Heuristic Methods
- Advanced Motion Control: Feedforward, Cascaded Loops, and Gravity Compensation
Robot Kinematics Explained
Master the spatial geometry of robots: Degrees of freedom, homogeneous transformation matrices, Forward Kinematics (DH parameters), Inverse Kinematics, Jacobians, and mobile robot wheel odometry.
- Degrees of Freedom (DOF): Planar, Spatial, and Grubler's Criterion
- Coordinate Frames and SE(3) Homogeneous Transformation Matrices
- Forward Kinematics (FK): Mapping Joint Space to Cartesian Space via DH Parameters
- Inverse Kinematics (IK): Analytic Closed-Form vs Numerical Damped Least Squares
- Differential Kinematics: The Jacobian Matrix and Singularities
- Mobile Robot Kinematics: Unicycle and Differential Drive Models
Robot Operating Systems: ROS 2 Architecture
Master the industry-standard robotics framework: DDS middleware, Nodes, Topics, Services, Actions, QoS profiles, TF2 coordinate transform trees, ros2_control, and the Nav2 navigation stack.
- Why ROS 2: DDS Decentralization, Real-Time Support, and Security
- The 7-Layer Stack: Hardware → Drivers → Nodes → Computation Graph
- Communication Primitives: Topics (Pub/Sub), Services, and Preemptible Actions
- Quality of Service (QoS): Reliability, Durability, and Liveliness Policies
- Coordinate Frames with TF2: map → odom → base_link → sensor_frames
- Actuation with ros2_control: Hardware Interfaces and Real-Time Controllers
- Autonomous Navigation with Nav2: Global Costmaps, Planners, and Recovery
SLAM in Robotics: Mapping & Localization
Master how autonomous robots navigate unknown worlds: The SLAM chicken-and-egg problem, 2D/3D LiDAR scan matching, Visual SLAM, Pose Graph Optimization, loop closure, and occupancy grids.
- The Chicken-and-Egg Dilemma: Why Localization and Mapping are Coupled
- Sensor Modalities: 2D LiDAR, 3D Point Clouds, and Visual SLAM (vSLAM)
- Front-End Scan Matching: Iterative Closest Point (ICP) and Correlative Matching
- Back-End Optimization: Factor Graphs, Pose Graphs, and GTSAM Solvers
- Loop Closure: Eradicating Odometry Drift with Visual and Geometric Descriptors
- Map Representations: 2D Occupancy Grids, 3D OctoMaps, and Feature Landmarking
Computer Vision in Robotics
Master robotic perception: Global vs rolling shutter, pinhole camera calibration, lens distortion, classical OpenCV processing, YOLO neural detection, stereo disparity, and 3D point cloud projection.
- The Sensor Pipeline: CMOS Rolling vs Global Shutter in Fast Motion
- Camera Geometry: Pinhole Model, Intrinsic Matrix K, and Distortion
- OpenCV Foundations: Color Spaces (HSV), Morphology, and Contours
- Fiducial Markers: AprilTags and ArUco for 6-DOF Pose Estimation
- Deep Learning at the Edge: YOLOv8/v11 Neural Object Detection
- Depth Perception: Stereo Disparity, Structured Light, and Time-of-Flight
- 2D-to-3D Spatial Projection: Unprojecting Pixels to Real-World Coordinates
Robot Localization & Sensor Fusion
Master how robots know where they are: Odometry drift, IMU integration bias, Kalman Filter predict-update math, Extended and Unscented Kalman Filters (EKF/UKF), and dual-instance ROS 2 localization.
- Why Single Sensors Fail: Wheel Slip, Gyro Drift, and GPS Dropouts
- State Estimation Foundations: Vectors, Covariances, and Gaussian Noise
- The Linear Kalman Filter (KF): Predict, Innovation, and Optimal Gain
- Non-Linear Realities: Extended Kalman Filter (EKF) vs Unscented (UKF)
- Dual EKF Architecture: Decoupling Local Odometry from Global World Frames
- Deploying robot_localization in ROS 2 with Real Sensors
Robot Mechanics & Chassis Design
Master physical robot engineering: Motor torque sizing formulas, drivetrain configurations (Differential, Ackermann, Mecanum), gearbox types, bearing load isolation, and materials selection.
- The Mechanical Reality: Why Perfect Code Fails on Weak Mechanics
- Motor Torque Sizing: Rolling Resistance, Incline Grade, and Acceleration
- Drivetrain Topologies: Differential vs Ackermann vs Omni/Mecanum vs Tracks
- Gearbox Engineering: Spur, Planetary, Worm, and Zero-Backlash Harmonic Drives
- Bearings and Load Isolation: Protecting Motor Shafts from Cantilever Forces
- Materials Selection: 6061 Aluminum, Carbon-Fiber, PA-CF vs The Acrylic Trap
- Chassis Dynamics: Center of Gravity (CG), Static Stability, and Tipping Prevention
Edge AI for Robotics
Master on-device robot intelligence: TinyML on microcontrollers vs Raspberry Pi SBCs vs NVIDIA Jetson GPUs and NPUs. Quantization (INT8), inference pipelines, latency, and power budgets.
- Cloud vs Edge: Why Robots Cannot Rely on Internet API Latency
- The Silicon Hierarchy: TinyML MCUs vs Quad-Core SBCs vs Edge GPUs & NPUs
- Model Optimization: FP32 to INT8 Quantization and TensorRT Layer Fusion
- Zero-Copy Vision Pipelines: V4L2 DMA-BUF to Tensor Acceleration
- Latency vs Power Budgets: Thermal Throttling, TDP, and Battery Sizing
- Silicon Selection Matrix: Matching AI Accelerators to Robotics Workloads
Autonomous Navigation & Path Planning
Master mobile robot trajectory generation: Global planners (A*, Dijkstra, RRT*), Local reactive planners (TEB, DWB, MPC), Nav2 costmap layers, and behavior recovery trees.
- The Navigation Hierarchy: Global Mission vs Local Obstacle Avoidance
- Global Path Planners: Graph Search (A*, Dijkstra) vs Sampling (RRT, RRT*)
- Local Reactive Controllers: DWB, Timed Elastic Band (TEB) & MPC
- 2D & 3D Costmaps: Static, Obstacle, Voxel & Inflation Decay Layers
- Nav2 Behavior Trees: Action Execution, Recovery, and Fallbacks
- Kinematic Constraints: Holonomic Omnidirectional vs Non-Holonomic Unicycle/Ackermann
LiDAR & 3D Point Cloud Processing
Master 3D spatial perception: Time-of-Flight (ToF) laser physics, Point Cloud Library (PCL), Voxel Grid filtering, RANSAC ground extraction, and ICP point cloud alignment.
- Time-of-Flight (ToF) Physics: Direct vs Phase-Shift vs FMCW Coherent Laser
- Sensor Topologies: 2D Spinning Mirrors, 3D Multi-Beam & Solid-State MEMS
- Point Cloud Data Representation: XYZ, Intensity, Ring, and Reflectivity Channels
- Preprocessing Filters: Voxel Grid Downsampling & Statistical Outlier Removal (SOR)
- Feature Segmentation: RANSAC Ground Plane Extraction & Euclidean Clustering
- Point Cloud Registration: Iterative Closest Point (ICP) & NDT Scan Matching
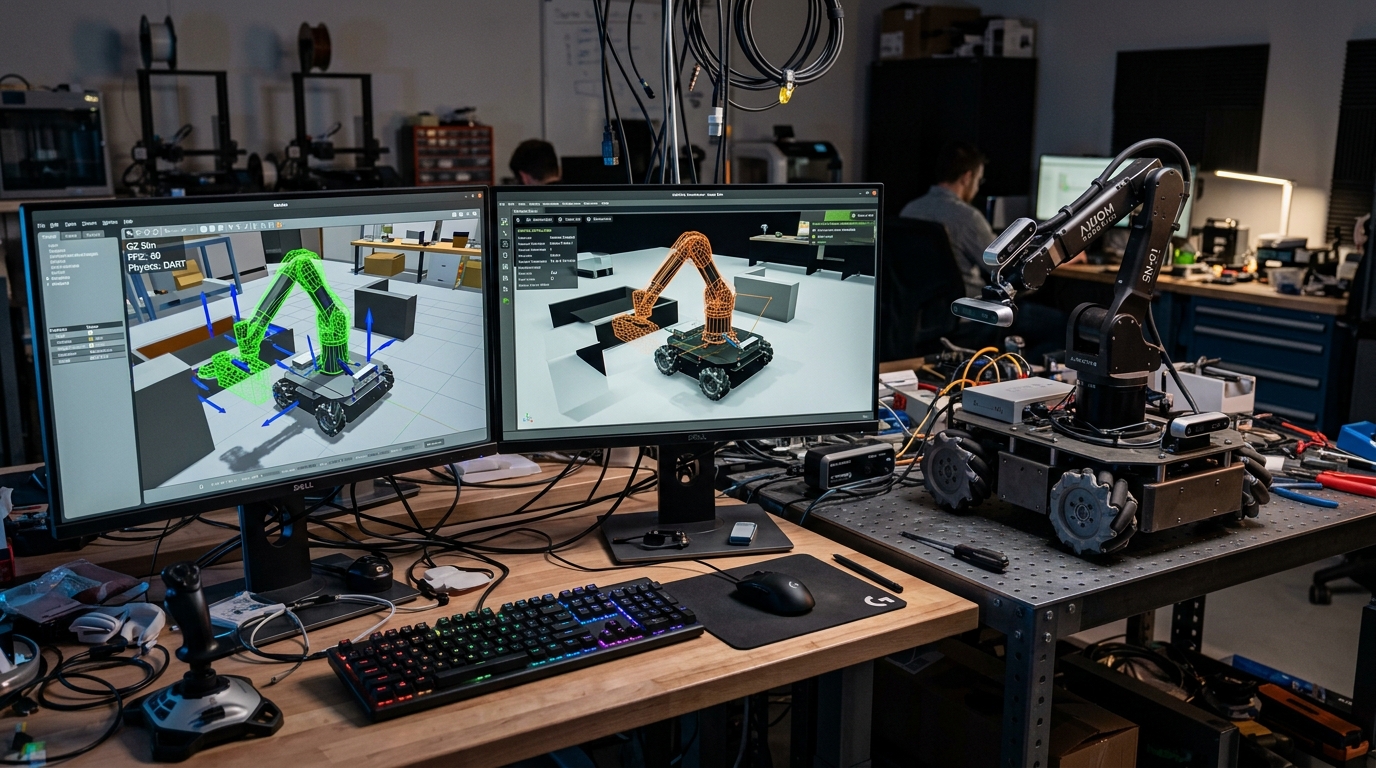
Robot Simulation & Digital Twins
Master virtual robotics development: Gazebo Harmonic vs NVIDIA Isaac Sim vs MuJoCo, URDF and SDF modeling, physical friction parameters, and Software-in-the-Loop (SITL) pipelines.
- The Sim-First Paradigm: Why Physical Prototypes Burn Without Digital Twins
- Simulation Engine Shootout: Gazebo Harmonic, NVIDIA Isaac Sim, MuJoCo & Webots
- Robot Model Formats: URDF vs Xacro vs SDF vs Universal Scene Description (USD)
- Physics Parameters: Inertial Tensors, Friction Cones & Restitution Coefficients
- Sensor Emulation: Simulated LiDAR Noise, RGB-D Artifacts & IMU Bias Drifts
- Software-in-the-Loop (SITL) & Hardware-in-the-Loop (HIL) CI/CD Testing
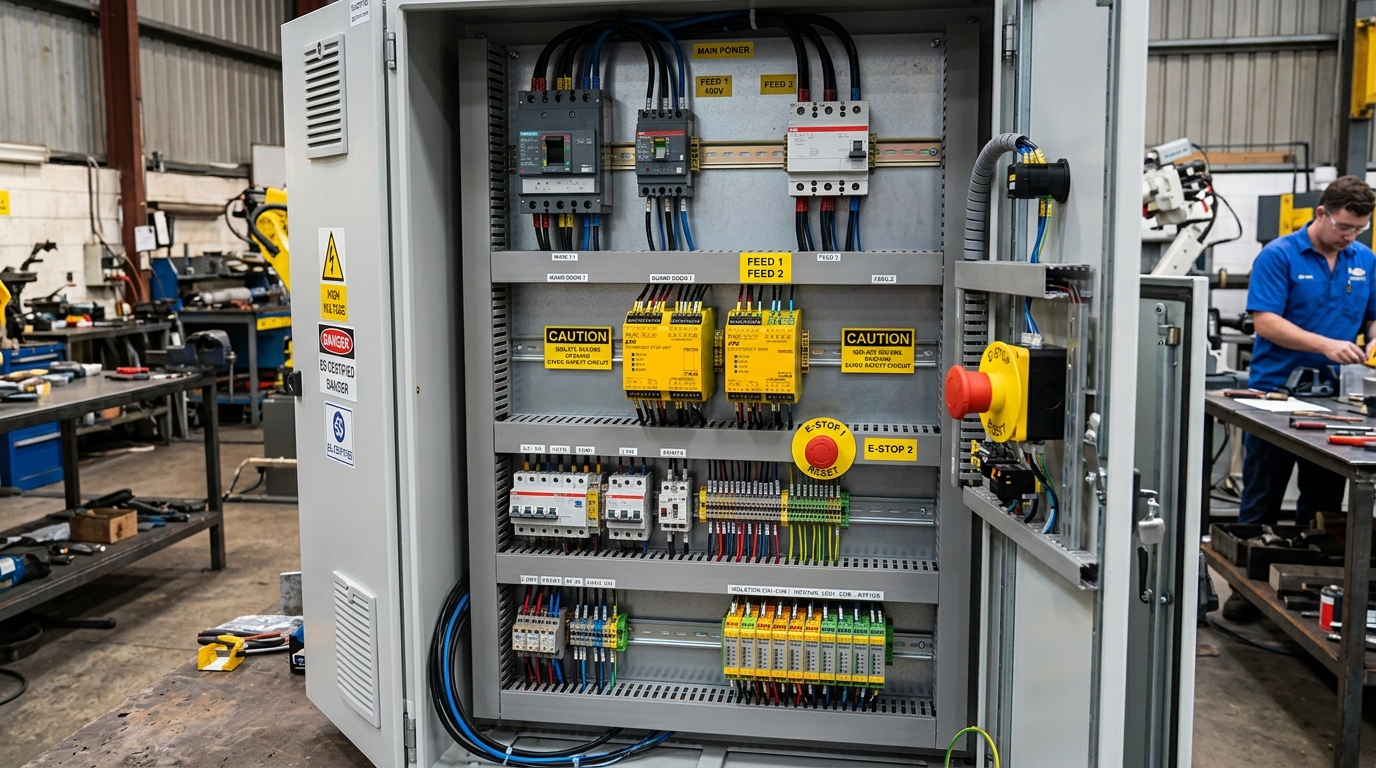
Safety & Fail-Safe Architectures
Master functional safety engineering: Safe Torque Off (STO), dual-channel E-Stop circuits, hardware watchdogs, galvanic isolation, and ISO 13849 / ISO 10218 standards.
- The Hierarchy of Robot Safety: Software vs Firmware vs Hardwired Interlocks
- Emergency Stop Circuits: Dual-Channel Category 3/4 Wiring & Pulsed Monitoring
- Safe Torque Off (STO) vs Mechanical Contactors vs Dynamic Braking
- Electrical Isolation: Optocouplers, Digital Isolators & Ground Loop Elimination
- Hardware Watchdog Timers & Heartbeat Safety Buses
- International Safety Standards: ISO 13849-1 (PL) & IEC 62061 (SIL) Demystified
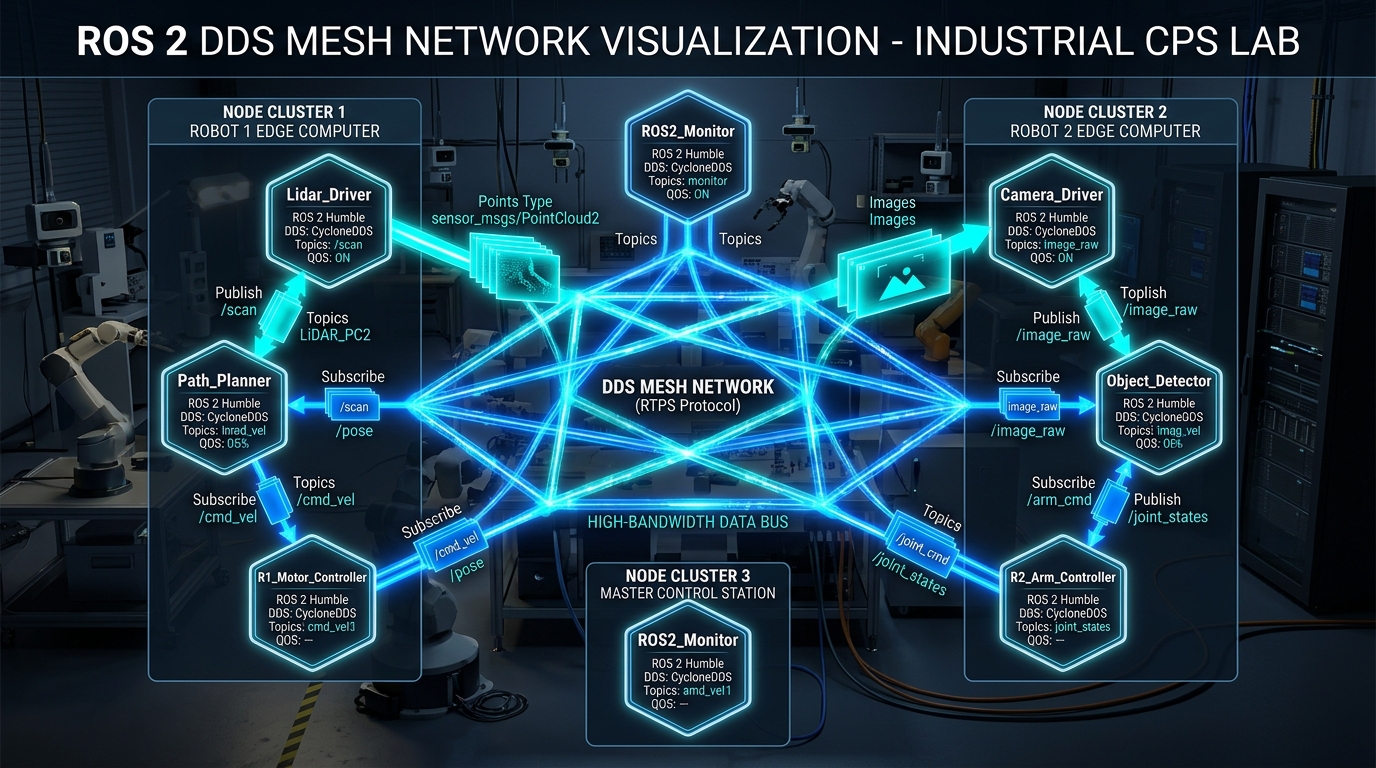
ROS 2 DDS Middleware & QoS Tuning
Master industrial ROS 2 networking: CycloneDDS vs FastDDS, Quality of Service (QoS) tuning, zero-copy shared memory (Iceoryx), multicast WiFi storms, and multi-robot fleet domains.
- Why ROS 2 Replaced TCP/UDP with DDS (Data Distribution Service)
- DDS Implementation Shootout: Eclipse CycloneDDS vs eProsima FastDDS
- Quality of Service (QoS) Profiles: Reliability, Durability, History & Liveliness
- Zero-Copy Transport: Loaned Messages & Eclipse Iceoryx for 4K Video and LiDAR
- Taming the WiFi Storm: Multicast Discovery vs Unicast Peer Lists in Warehouses
- Multi-Robot Fleet Networking: ROS_DOMAIN_ID, Subnets & DDS Discovery Servers
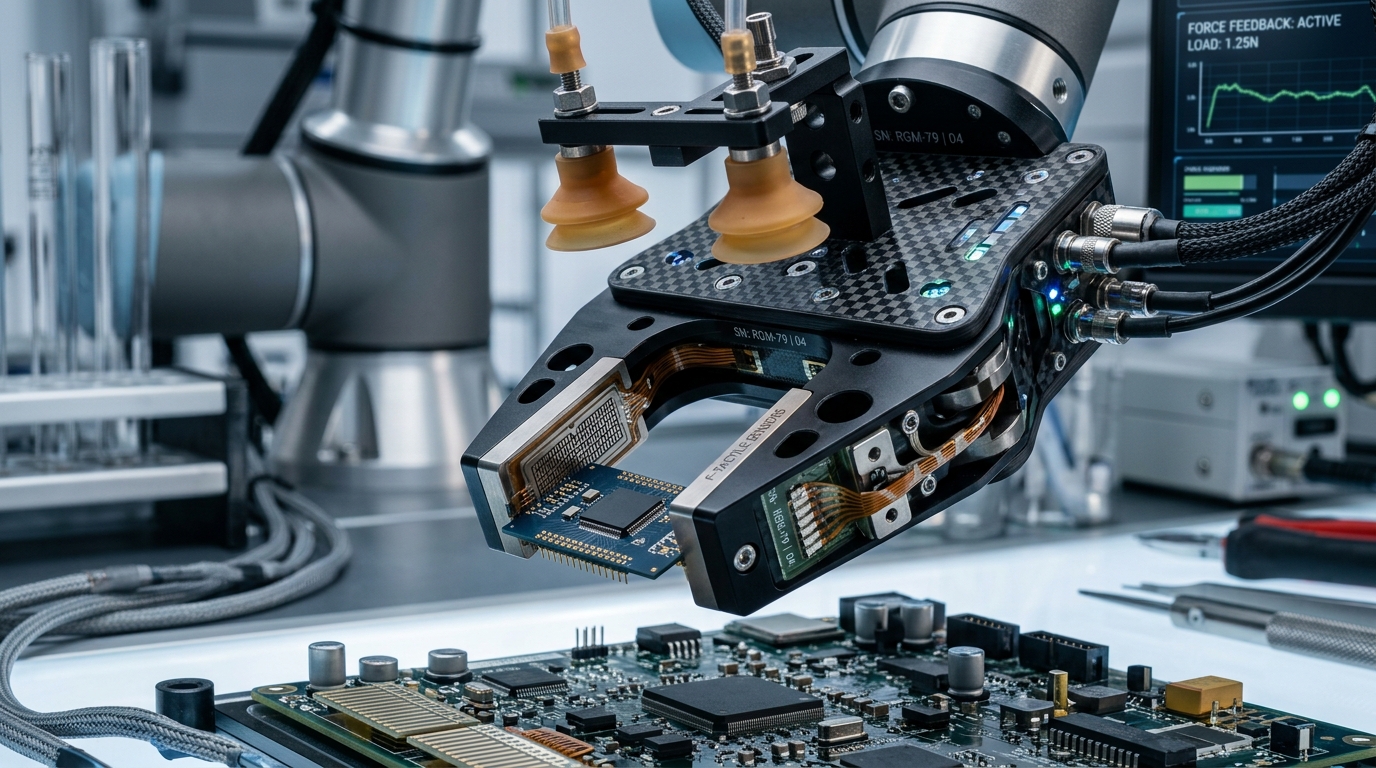
Robotic Grippers & End-Effectors
Comprehensive guide to robotic manipulation tooling: Parallel-jaw, vacuum suction, multi-finger dexterous hands, grasp mechanics (Form vs Force closure), tactile slip sensing, and pneumatic vs electric actuation.
- End-Effector Taxonomy: Parallel-Jaw, Suction, Soft & Dexterous Hands
- Grasp Mechanics: Form Closure vs Force Closure & Friction Cones
- Actuation Architectures: Electric Servo vs Pneumatics vs Underactuated Cables
- Tactile & Slip Sensing: Optical GelSight, Piezoresistive & 6-Axis F/T Cells
- Pneumatic Vacuum Physics: Venturi Ejectors, Cup Sizing & Flow Dynamics
- Grasp Planning & ROS 2 Control: Grasp Quality Metrics & GripperCommand Actions
Visual SLAM & Visual Odometry
Master camera-based localization and 3D mapping: Feature extraction (ORB/FAST), Epipolar geometry, Bundle Adjustment, Visual-Inertial Odometry (VIO) with IMU preintegration, and loop closure.
- Visual Odometry (VO) vs Full Visual SLAM vs Visual-Inertial (VIO)
- Feature-Based (ORB-SLAM3) vs Direct Photometric Approaches (DSO)
- Epipolar Geometry: Essential Matrix, Fundamental Matrix & 3D Triangulation
- Bundle Adjustment & Factor Graphs: Ceres, g2o & Non-Linear Optimization
- IMU Preintegration on Manifolds: High-Rate Accelerometer & Gyro Fusion
- Loop Closure & Drift Correction: Bag-of-Words (DBoW2) & Pose Graph Optimization
Robot Arm Motion Planning with MoveIt 2
Master 6-DoF/7-DoF manipulator trajectory generation: Forward & Inverse Kinematics (TRAC-IK, IKFast), Collision checking with FCL & OctoMap, OMPL sampling (RRT-Connect), and TOPP-RA time parameterization.
- The Manipulator Motion Hierarchy: Cartesian Pose to Joint Splines
- Inverse Kinematics Solvers: Numerical (TRAC-IK) vs Analytical (IKFast)
- Collision Detection: Planning Scene Monitor, FCL Meshes & OctoMap Voxels
- Sampling-Based Planners: OMPL RRT-Connect, PRM* vs TrajOpt Optimization
- Time Parameterization: Time-Optimal Path Parameterization (TOPP-RA)
- MoveIt 2 C++ Architecture: MoveGroupInterface, Pilz Industrial & Hybrid Planners
BMS & Battery Thermal Management
Master mobile robot energy storage engineering: LiFePO4 vs NMC chemistries, BMS protection architectures, Extended Kalman Filter SOC estimation, cell balancing, and thermal runaway prevention.
- Energy Storage Chemistries: LiFePO4 (LFP) vs NMC vs LTO for Heavy AMRs
- BMS Protection Architecture: High-Side Solid-State Switching & Pre-Charge
- State of Charge (SOC) & Health (SOH): Coulomb Counting vs Dual-EKF
- Cell Balancing Dynamics: Passive Bleeding vs Active Inductive Energy Transfer
- Thermal Runaway Prevention: Heat Generation Math & Cooling Strategies
- Telemetry & ROS 2 Integration: CAN Bus to sensor_msgs/BatteryState
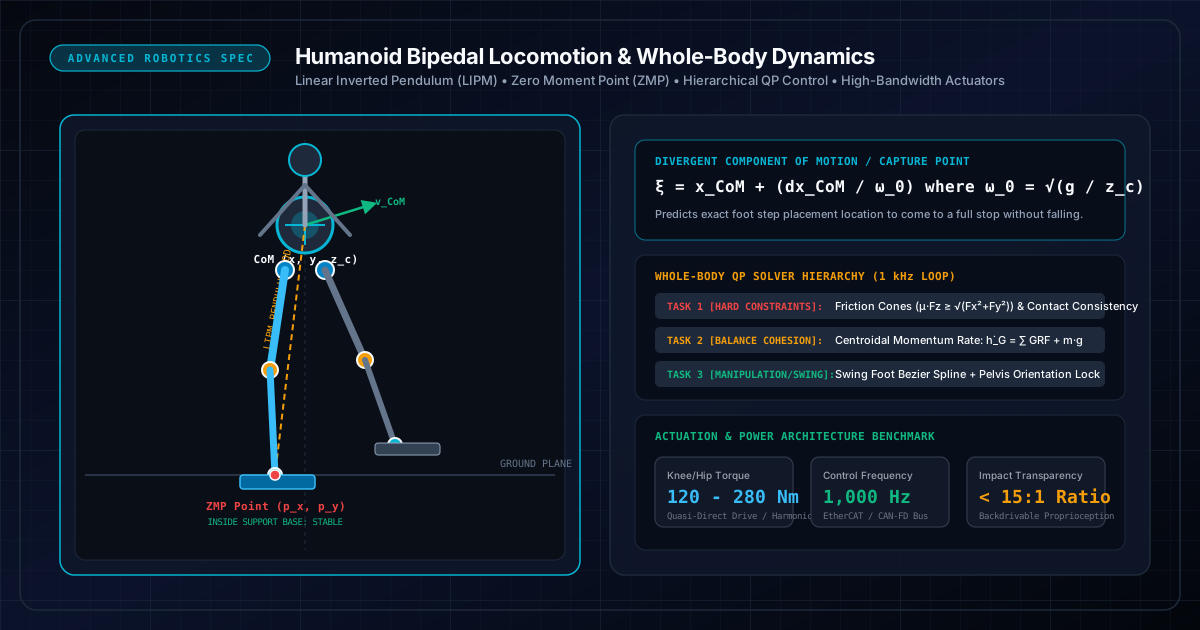
Humanoid Robotics & Bipedal Locomotion
Master modern bipedal humanoid robotics: Linear Inverted Pendulum (LIPM), Zero Moment Point (ZMP), Capture Point balance, Hierarchical Whole-Body QP Control, and high-torque actuator dynamics.
- The Physics of Walking: Linear Inverted Pendulum Model (LIPM)
- Dynamic Stability: Zero Moment Point (ZMP) & Capture Point (DCM)
- Hierarchical Whole-Body Control: Quadratic Programming (QP) Solvers
- Actuation Dynamics: Quasi-Direct Drive (QDD) vs Harmonic Transmissions
- Model Predictive Control (MPC): Real-Time Ground Reaction Force Optimization
- Sim-to-Real Deployment: 1 kHz EtherCAT, MuJoCo Physics & Reinforcement Learning
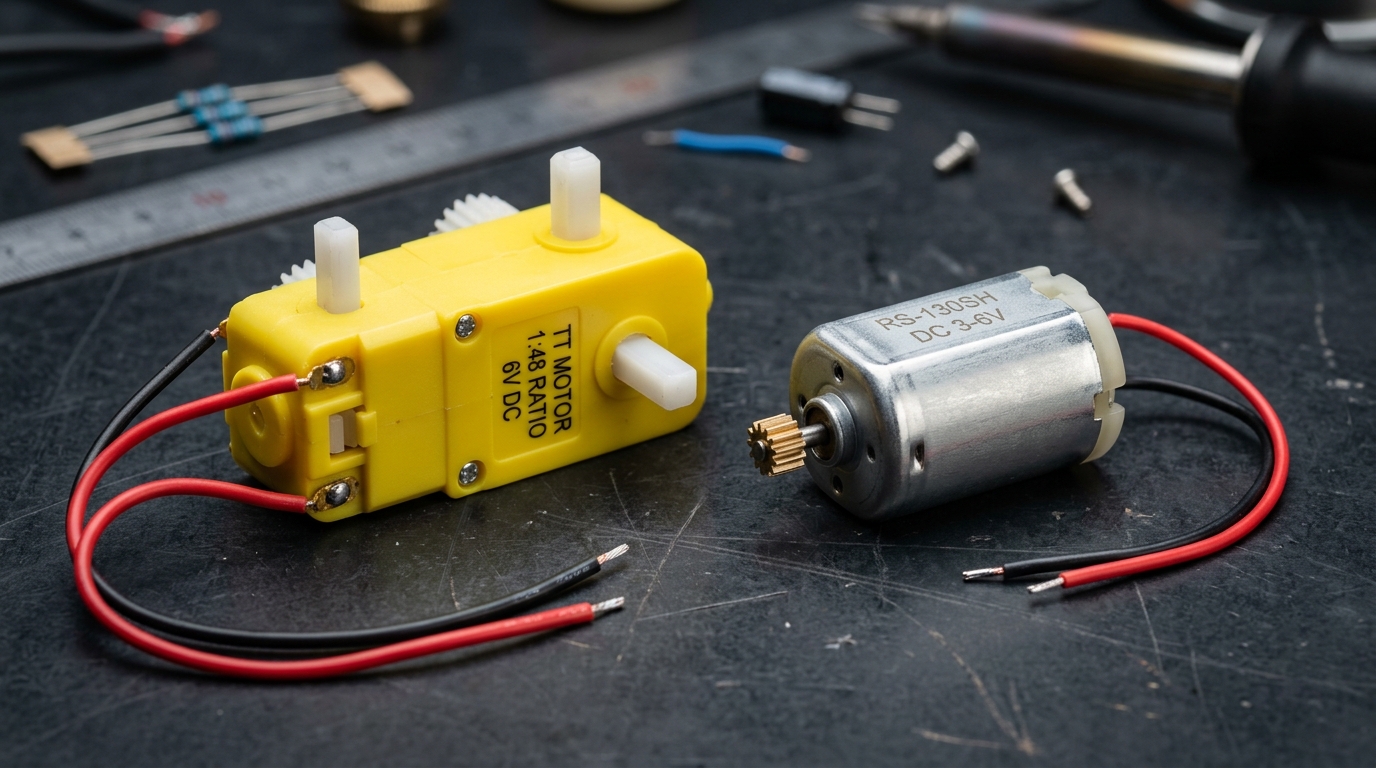
Motors in Robotics
Beginner-friendly guide to DC brushed, BLDC, stepper, and servo actuators with simple wiring, speed control, and motor drivers.
- How Electric Motors Work (Simple Core Physics)
- DC Brushed Motors (Simple 2-Wire Workhorse)
- Brushless DC Motors (BLDC & Drone Power)
- Stepper Motors (Extreme Precision Steps)
- RC Servos & Smart Serial Actuators
- Motor Drivers, H-Bridges & Circuit Safety
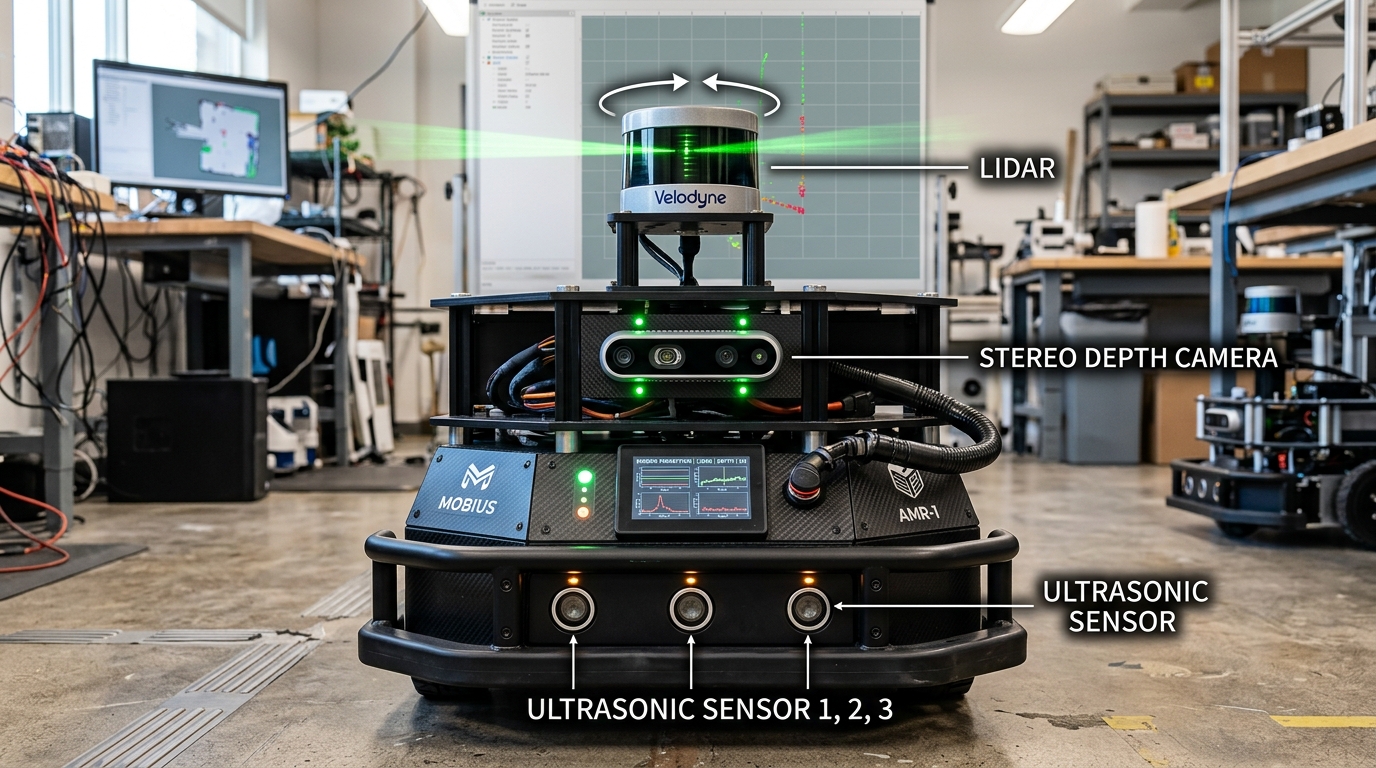
Sensors in Robotics
Master how robots see and feel their surroundings: wheel encoders, gyro IMUs, ultrasonic sensors, 2D LiDAR, and depth cameras.
- How Robots Sense the World (Inside vs Outside)
- Wheel Encoders & MPU-6050 Gyro/IMUs
- Ultrasonic (HC-SR04) & Laser Distance Sensors
- 2D Rotating LiDAR for Room Mapping (SLAM)
- RealSense Depth Cameras & Clean Sensor Fusion
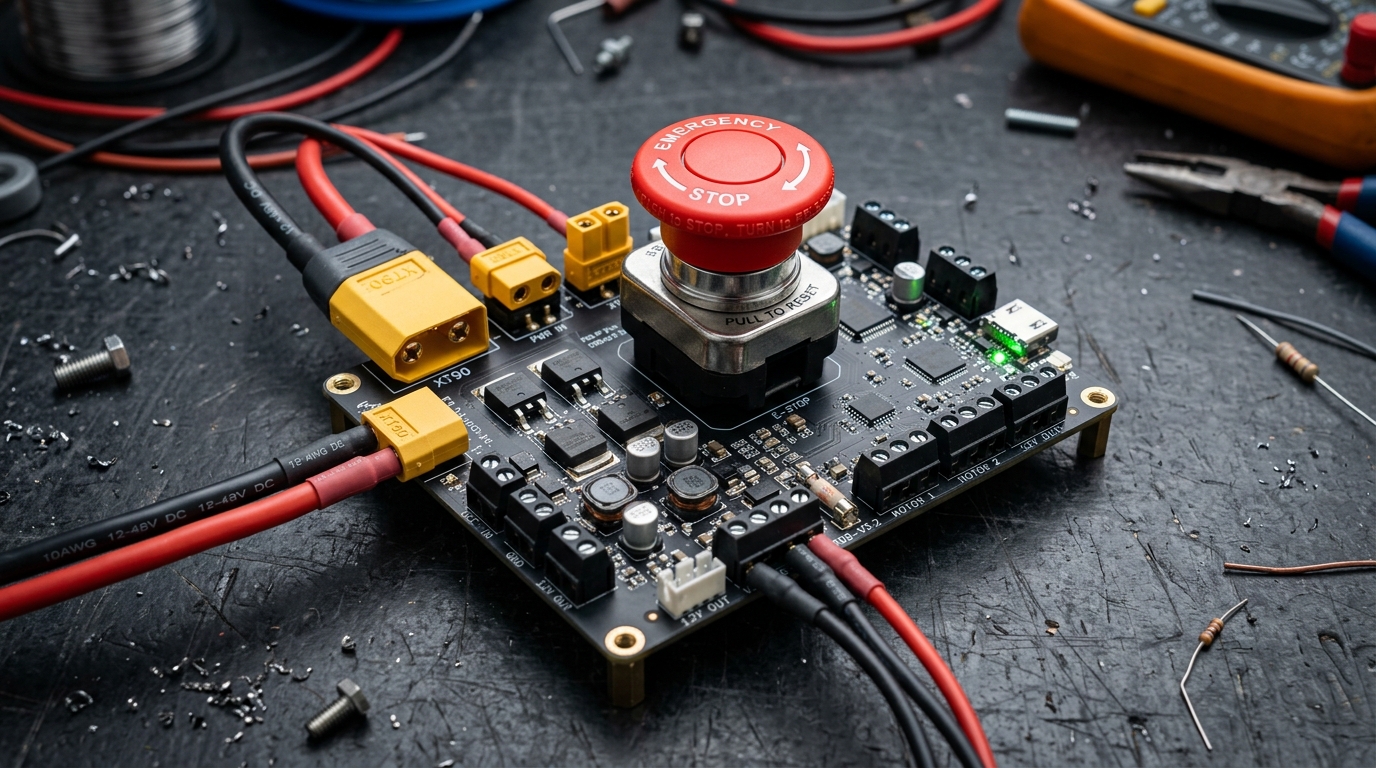
Power System in Robotics
Learn how to power robots safely: LiPo vs 18650 batteries, BMS safety protection boards, DC-DC step-down converters, and E-Stops.
- How Robot Power Systems Work (Safe Energy Flow)
- Battery Types (LiPo Drones vs 18650 vs LiFePO4)
- C-Ratings & Battery Runtime Calculations
- BMS Protection Boards (Why Batteries Need Them)
- DC-DC Step-Down Regulators (5V/12V Power)
- Emergency Stops (E-Stop) & Safe Wiring
How the Three Pillars Connect in a Robot
Every autonomous system operates as a closed loop: Power provides clean electrical rails, Sensors capture environmental and joint telemetry, and Motors translate software commands into physical force.
1. Power System (Energy Bus)
Provides raw high-current battery power (12V–48V) to motor inverters while stepping down to ultra-stable 5V/3.3V logic rails with star grounding to prevent noise injection.
Explore Power Architecture2. Sensors & Telemetry (Perception)
Encoders measure wheel rotation ticks, IMUs quantify angular acceleration, and LiDAR + Depth Cameras map obstacles for real-time Kalman filter state estimation.
Explore Sensor Suite3. Motors & Drivers (Actuation)
H-Bridges, ESCs, and FOC inverters convert software PWM and velocity commands into mechanical torque, driving wheels, joints, and end-effectors with high efficiency.
Explore Actuation SystemsReady to apply this knowledge in hands-on projects?
Explore our 8 career roadmaps or build one of our 12 complete open-source robots with schematics and BOMs.